namo We integrated arnavi protocol. Supported devices are: Arnavi Integral 1 Arnavi Integral 2 Arnavi Integral 3 Arnavi 4 Arnavi 5 Arnavi Beacon Currently the protocol is implemented at basic level: only gps position, inputs, lbs, mileage and some other parameters are parsed. If you are interested in deeper protocol integration, please contact us in flespi chat.
namo Arnavi protocol updated: new parameters added: tags 10-17 IMPS_0 - IMPS_7 are registered as counter.impulses.1 - counter.impulses.8 tags 20-27 FREQ_0 - FREQ_7 are registered as frequency.counter.din.1 - frequency.counter.din.8 tags 30-37 VOLT_0 - VOLT_7 are registered as ain.1 - ain.8 bug fixed: tag 9 Device status, bits 24-31 external voltage - parameter external.powersource.voltage in flespi - was mistakenly multiplyed by 10. Now it's parsed correctly.
namo Arnavi protocol updated: added tags 50 - 79. Mapping to flespi parameters is below: tag 50 can_log_number - can.log.number tag 51 can_security_state - registered bitwise: bit0 - bit2 - car.remote.control.state bit6 - can.module.sleep.mode bit8 - can.driver.door.status bit9 - can.passenger.door.status bit10 - can.trunk.status bit11 - can.hood.status bit12 - can.handbrake.status bit13 - can.pedal.brake.status bit14 - can.engine.status bit15 - can.webasto.status bit16 - can.engine.ignition.status bit17 - factory.alarm.actuated.status bit18 - can.car.closed.remote.status bit19 - can.ignition.key.status bit20 - can.dynamic.ignition.status bit21 - can.rear.left.door.status bit22 - can.rear.right.door.status tag 52 CAN - total engine operating time (hours) - can.engine.motorhours tag 53 CAN - full run TC (km) - can.vehicle.mileage tag 54 CAN - full fuel consumption (l) - can.fuel.consumed tag 55 CAN - the fuel level in the tank (%) - can.fuel.level tag 56 CAN - the fuel level in the tank (l) - can.fuel.volume tag 57 CAN - engine speed (rpm) - can.engine.rpm tag 58 CAN - engine temperature (C) - can.engine.temperature tag 59 CAN - Vehicle speed (km / h) - can.vehicle.speed tag 60 CAN - the pressure on the axle 1 (kg) - can.axle.weight.1 tag 61 CAN - the pressure on the axle 2 (kg) - can.axle.weight.2 tag 62 CAN - the pressure on the axle 3 (kg) - can.axle.weight.3 tag 63 CAN - the pressure on the axle 4 (kg) - can.axle.weight.4 tag 64 CAN - the pressure on the axle 5 (kg) - can.axle.weight.5 tag 65 CAN - can_accident flags - registered bitwise: bit6 - can.passenger.seatbelt.indicator.status bit7 - can.driver.seatbelt.indicator.status bit8 - can.esp.indicator.status bit9 - can.glow.plug.indicator.status bit10 - can.soot.filter.indicator.status bit11 - can.electronic.power.control.status bit12 - can.parking.lights.status bit13 - can.low.beam.status bit14 - can.high.beam.status bit16 - can.check.engine.indicator.status bit17 - can.lights.failure.indicator.status bit18 - can.tire.pressure.low.status bit19 - can.wear.brake.pads.indicator.status bit20 - can.warning.indicator.status bit21 - can.abs.failure.indicator.status bit22 - can.fuel.level.low.indicator.status bit24 - can.stop.indicator.status bit25 - can.oil.pressure.indicator.status bit26 - can.coolant.level.low.indicator.status bit27 - can.handbrake.indicator.status bit28 - can.battery.indicator.status bit29 - can.airbag.indicator.status tag 66 CAN - Status Flags agricultural equipment - can.agro.equipment.bitmask tag 67 CAN - The fluid level AdBLUE (%) - can.adblue.level tag 68 CAN - The fluid level AdBLUE (L) - can.adblue.volume tag 69 CAN - driving_state: byte1 - can.throttle.pedal.level byte2 - can.engine.load.level byte3&4 - can.movement.state.bitmask tag 70 LLS_0: byte1&2 - lls.value.1 byte3 - lls.temperature.1 byte4 - ble.asset.battery.voltage.1 ... tag 79 LLS_9: byte1&2 - lls.value.10 byte3 - lls.temperature.10 byte4 - ble.asset.battery.voltage.10
baja The protocol will be affected by the change in type of parameters gsm.mcc and gsm.mnc to be installed in 2 weeks - May 23rd, 2022: both parameters that now have type "string" will be stored as "number". The possible leading zeroes in MNC will be ignored (e.g. the value "01" will be stored as 1).
namo Arnavi protocol is updated: the following parameters are renamed: can.driver.door.status is renamed to can.front.left.door.status can.passenger.door.status is renamed to can.front.right.door.status For backward compatibility both old and new parameters will be registered for 1 more week. Old parameters can.driver.door.status and can.passenger.door.status will be removed 01-Nov-2022. Please, switch your applications to the new names of parameters until then.
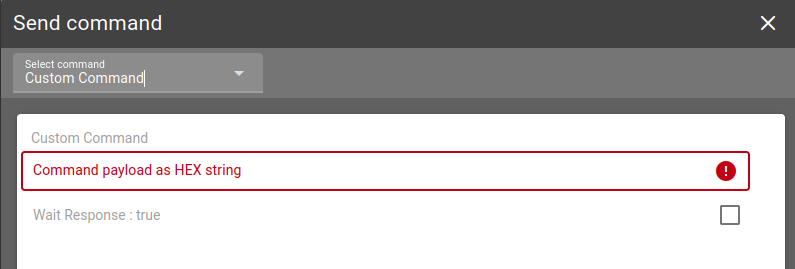
baja Optional field wait_response added for custom command when false, command is marked as executed right after being sent to TCP connection
bird New scooter telemetry parameters from tag 190 (virtual sensor) subtags: vehicle.speed, scooter.battery.level, battery.level, vehicle.state.bitmask, vehicle.type, external.battery.level, ecu.error.code, trip.mileage, scooter.motor.error.code, scooter.bms.error.code
bird New device status parameters from tag 99 (DS2) bit-level parsing: device.state.bitmask, gnss.state.enum, gsm.state.enum, sim.card.slot, sim.card.state, movement.status, case.status, sdcard.log.enum, bluetooth.state, gyroscope.state.enum, wifi.state